Dynamics of the Control Loop
To assess how the controlled system behaves over time, we again use the step response. With it we can characterise not only function blocks but also entire controlled systems. To do this, a step from 0 to 1 is initiated in the reference variable w. Then the output quantity y is measured over time. For a system with P behaviour and A = 9, the following curve results:
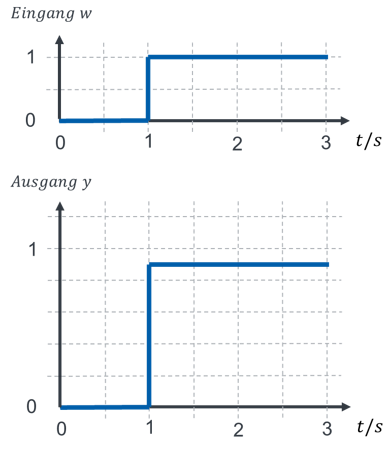
The reference variable steps from 0 to 1. The controlled variable y jumps to the value 0.9 ∙ w = 0.9. The controlled variable y jumps at the same time as the reference variable w. There is no time delay. Overall, the controlled system shows P behaviour with kP = 0.9. From the step response we recognise the following relationship:
A function block has input and output quantities. It has a behaviour with characteristic parameters. The same applies to controlled systems. They too have input and output quantities as well as a behaviour with characteristic parameters.
Definition of terms
We have to be careful with the terms and subscripts. In the example above, A shows P behaviour. So the behaviour of controller, actuator and plant together is P behaviour with kP = 9. The controlled system also shows P behaviour, with HFÜ = 0.9.
The term reference response is only defined for controlled systems. So for controlled systems we give the transfer function of the reference response HFÜ to describe the system. For function blocks we give kP with different subscripts instead. We denote the gain of an actuator, for example, as kPA, and that of a plant as kPS.