Summary
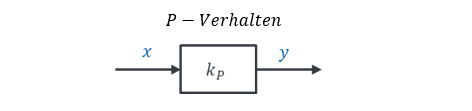
\[
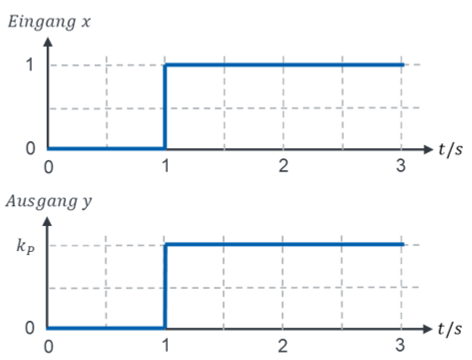
k_P = \frac{y}{x} = \text{constant}
\]
\[
\begin{gathered}
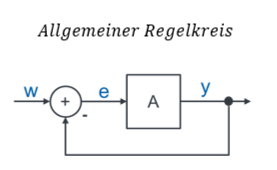
H_{\mathrm{FÜ}} = \frac{A}{1 + A} \\[6pt]
\frac{e}{w} = \frac{1}{1 + A} \\[6pt]
\text{with } w = 1 \text{ (step): } e = \frac{1}{1 + A} \\[6pt]
\text{Goal: } y = w \text{ and } e = 0 \\[6pt]
\text{with } A = k_P \\[6pt]
H_{\mathrm{FÜ}} = \frac{k_P}{1 + k_P} < 1
\end{gathered}
\]